
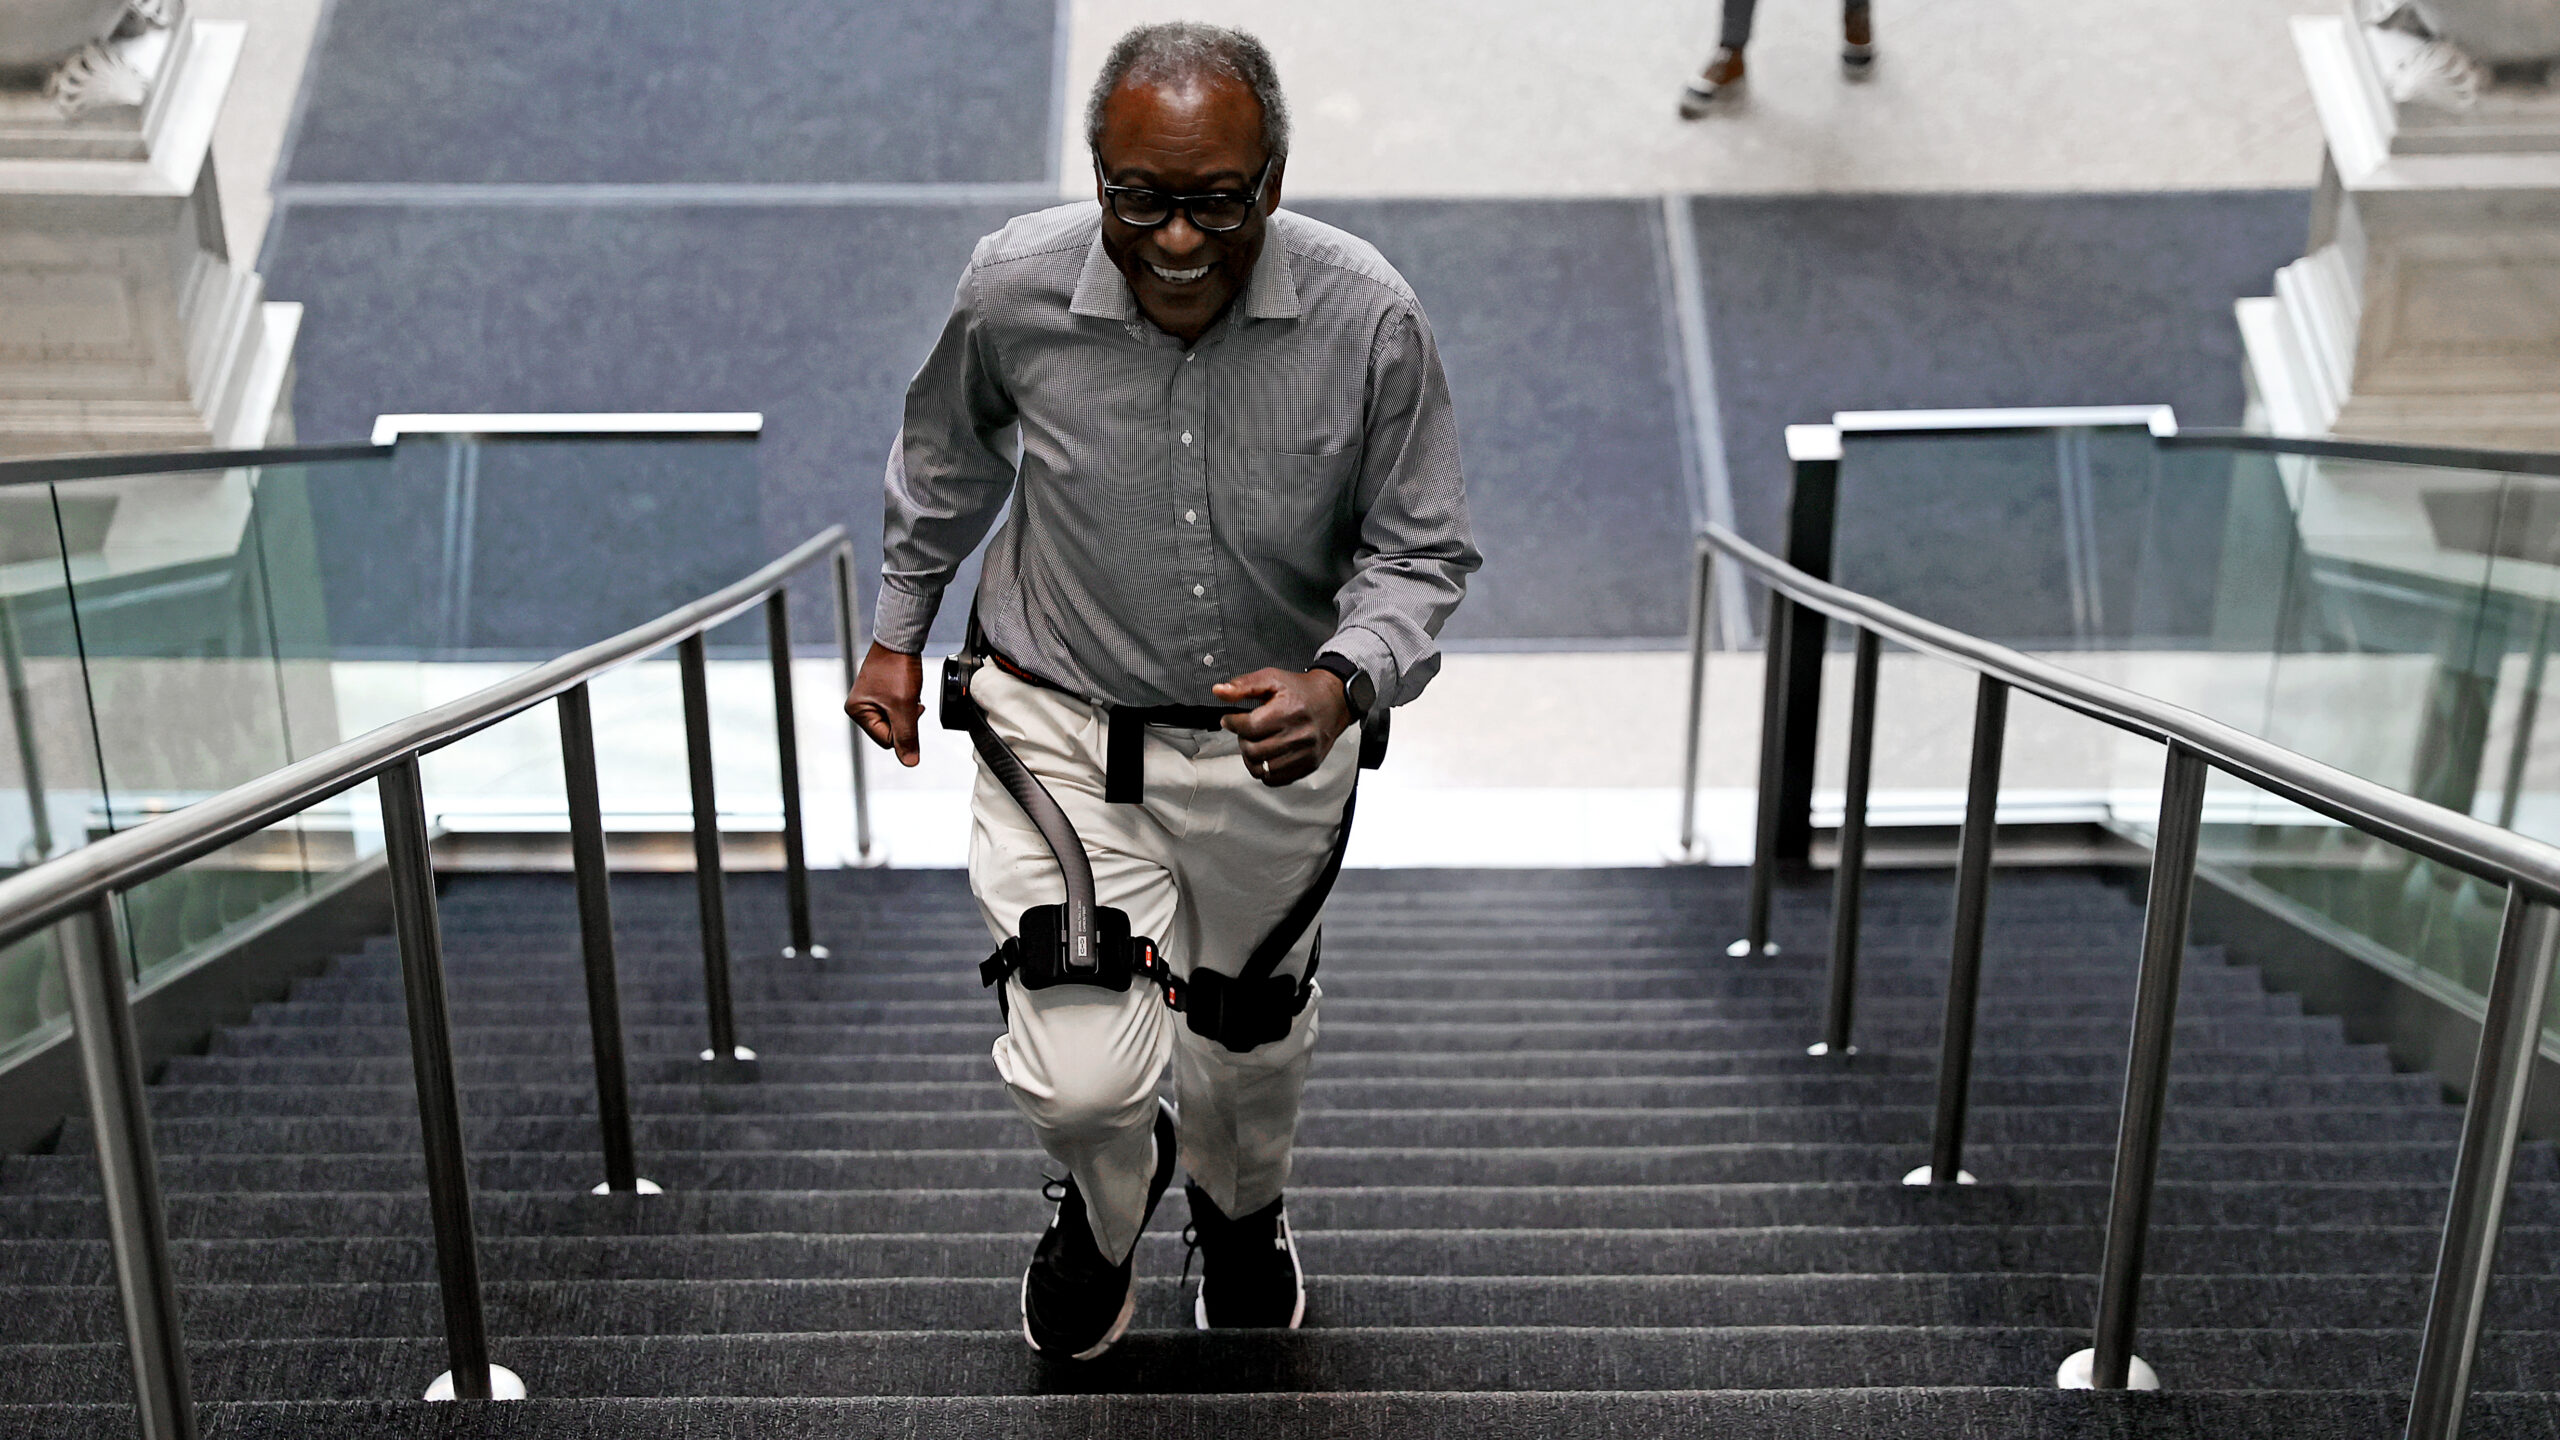
One of the earliest known concepts was patented in 1890 by Nicholas Yagn, a self-taught Russian inventor, who designed a wearable apparatus for exercising. In 1919, American Leslie C. Kelley received a patent for a steam-powered device to support walking, one of the first powered exoskeleton concepts. By the end of the 1960s, multiple actuated robotic exoskeletons incorporating electronic control systems had been developed. Since then, research and development has advanced rapidly, leading to devices with commercial and clinical applications.
Modern, active robotic exoskeletons typically consist of a lightweight mechanical frame with ergonomic attachments to the human body, usually affixed at the trunk, waist, and to upper or lower limbs. For example, the Hypershell device seen in Ukraine attaches to the user’s waist and thighs to assist with hip flexion and extension and strengthen lower-body movement. The Suit X device used by IKEA attaches to the torso and upper limbs to support the back and shoulders. In most powered exoskeletons, actuators convert electric power from batteries into mechanical movement, generating forces that support or enhance the body’s movement. These are coordinated by control units embedded in the exoskeleton, which define movement trajectories and force application. Exactly how the device moves depends on the task and user state, with sensors determining needs; if a wearer starts running, the device speeds up supportive movements, and if fatigue is sensed, power output may increase.
These devices continue to show noticeable benefits for users in various real-world tasks.
Source: Ars Technica · Summarized by HeadlinesBriefing